BOROSILICATE SPHERE OPTICS // FOV 110°
DEA WAVE PROPULSION + MHD STEERING
WebGPU Fluid & Optical Sim EPI-MESOPELAGIC ZONE

WADATSUMI-01 Hadal Glider

Biomimetic Deep-Sea Exploration Drone — DEA Wave Fin & Underwater Optical Simulation

DEPTH 240 m
PRESSURE 25.0 ATM
SPEED 3.8 kt
60 FPS 65.5K PTCL
scuba_diving DEPTH 240m
Design & Blueprint arrow_downward
CONCEPT & INDUSTRIAL DESIGN SHEET

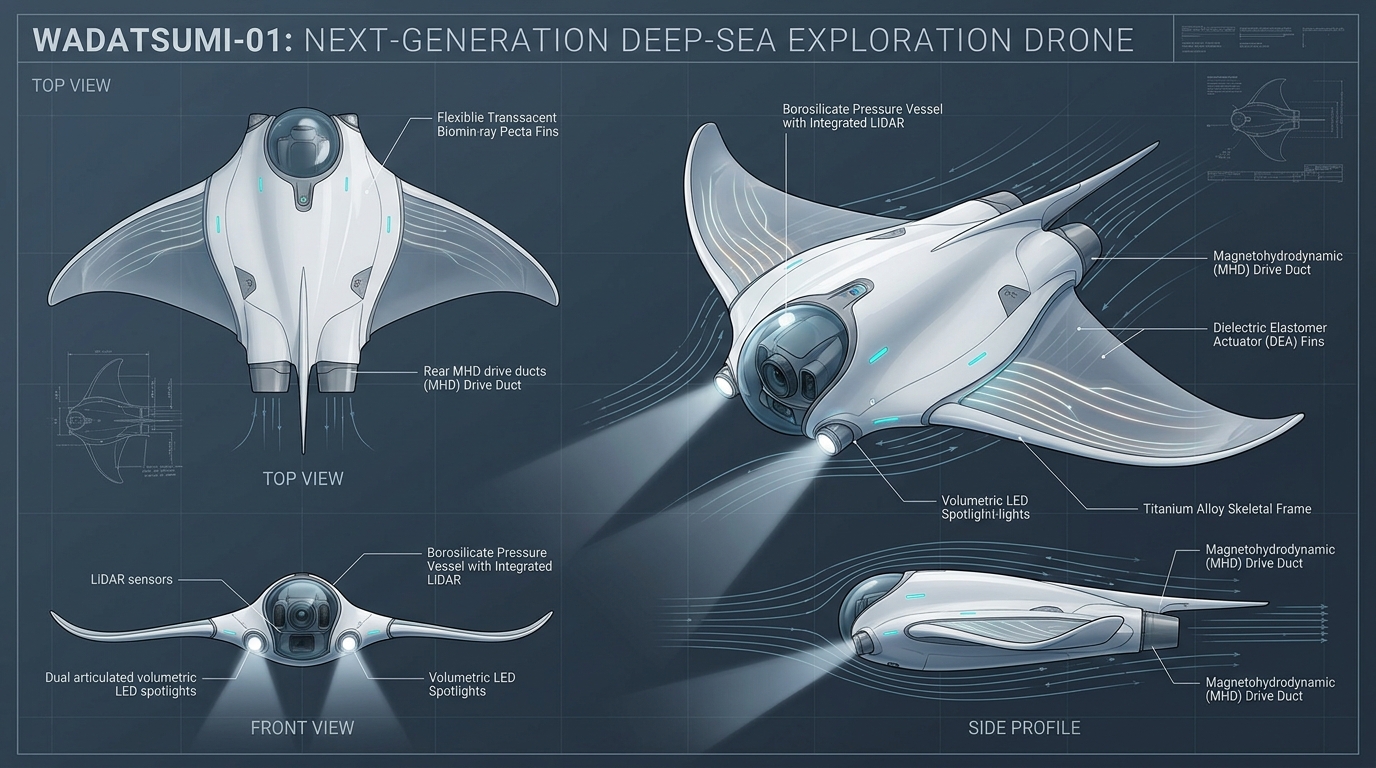
WADATSUMI-01 Engineering Blueprint

WADATSUMI-01 Orthographic Blueprint

01 // ORTHOGRAPHIC ENGINEERING BLUEPRINT

Integrates a central borosilicate spherical pressure vessel with translucent dielectric elastomer actuator (DEA) undulating fins and twin silent magnetohydrodynamic (MHD) water-jet ducts.

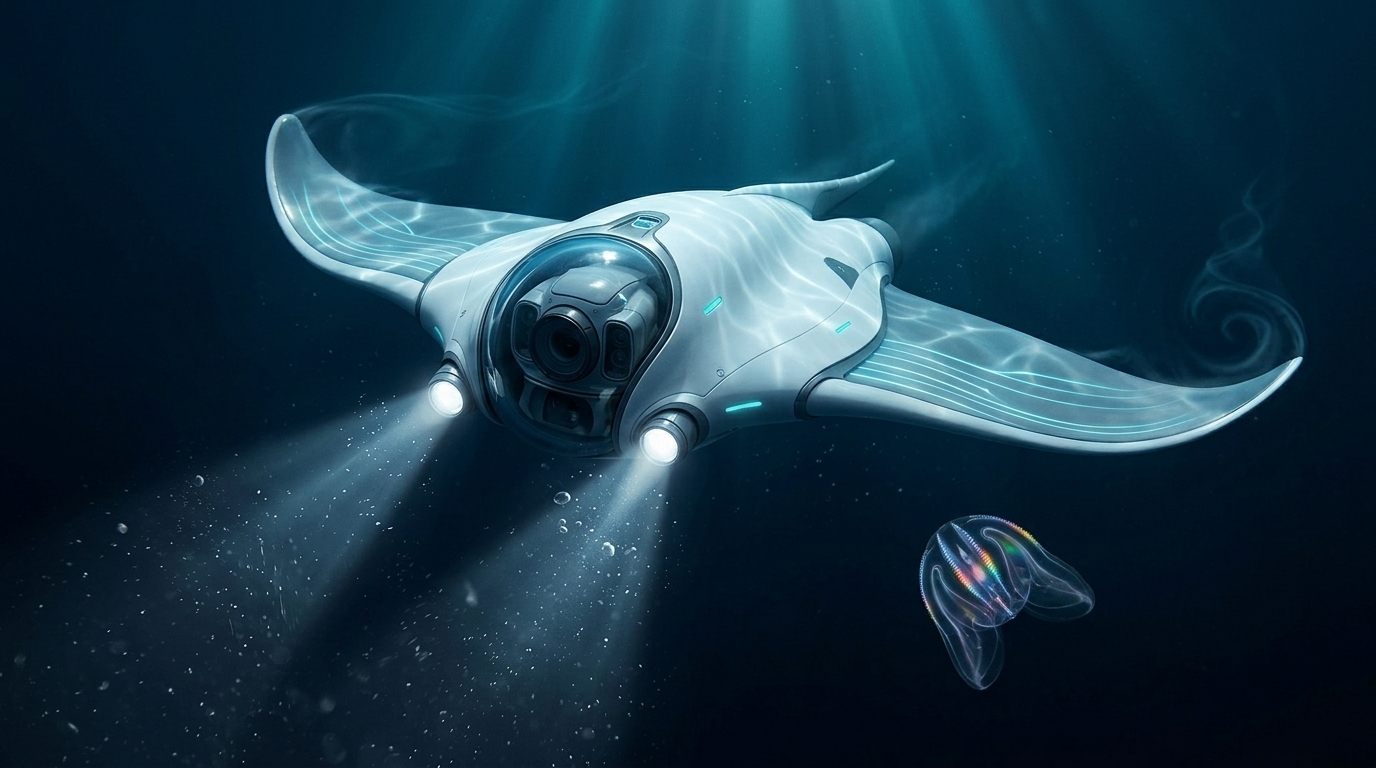
WADATSUMI-01 Underwater Concept

02 // IN-SITU HYDRODYNAMIC & OPTICAL RENDER

Volumetric solar shafts (God rays), real-time optical caustics on the white titanium hull, Tyndall scattering inside dual narrow-beam spotlights, and gentle wingtip vortex wakes.

SILENT BIOMIMETIC FIN

Eliminates noisy screw propellers that stir up benthic silt or shred fragile gelatinous lifeforms, gliding silently with manta-like wave propulsion.

BOROSILICATE GLASS CORE

A spherical borosilicate housing that gains compressive strength under extreme hadal pressure while providing an unobstructed panoramic optical viewport.

BIO-RESONANCE OPTICS

Replaces blinding floodlights with narrow-cone beams, red stealth navigation, and wavelength-tunable bioluminescent resonance pulses.

CONCEPTUAL HARDWARE & WEBGPU SIMULATION

Exploring the Abyss Without Disturbing Its Silence.

Conventional thruster-driven ROVs kick up clouds of benthic sediment and generate turbulent shear that damages delicate gelatinous organisms like comb jellies. WADATSUMI-01 reimagines deep-sea exploration through biomimetic wave propulsion, silent MHD jets, and physically grounded underwater optics in WebGPU.

WADATSUMI-01 Engineering Blueprint
STEP 01 // HARDWARE ARCHITECTURE

Orthographic Blueprint & Biomimetic Mechanics

Built around a 600-ATM borosilicate glass pressure sphere, flanked by dielectric elastomer actuator (DEA) pectoral fins that undulate in a traveling sine wave, and backed by twin magnetohydrodynamic (MHD) water-jet ducts with zero moving parts.

MAX DEPTH 6,000 m
ACOUSTIC NOISE < 18 dB
WINGSPAN 2.40 m
WADATSUMI-01 Underwater Optics
STEP 02 // UNDERWATER OPTICS & FLUIDS

Physically Grounded Water Realism in WebGPU

Authentic underwater atmosphere comes from light scattering and fluid viscosity: volumetric crepuscular rays, live optical caustics projected across the curved hull, 65,536 marine snow particles glittering via forward Mie scattering inside the twin spotlight cones, and counter-rotating wingtip vortex wakes computed in WGSL.

COMPUTE PARTICLES 65,536
FLUID FIELD 3D Curl + Wake
OPTICAL SHADER Mie + Caustics